Raspberry Pi HAT · Flight controller
flightHAT
Turn a Raspberry Pi into a Pixhawk-class drone.
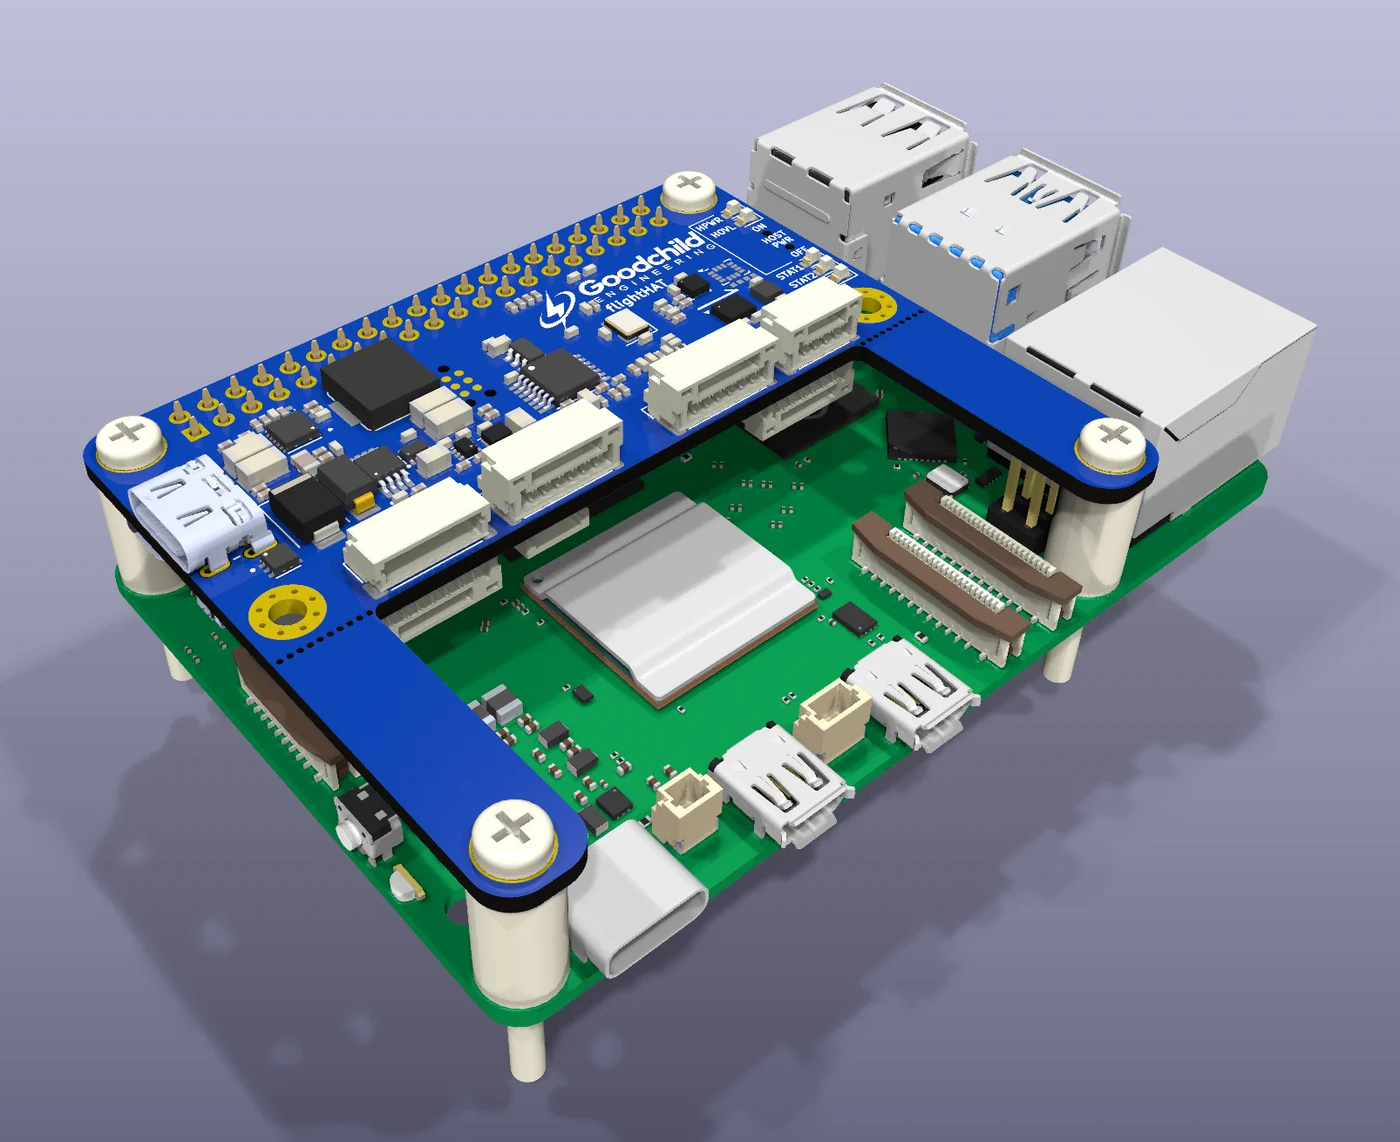
flightHAT turns a Raspberry Pi into a Pixhawk-class drone: a real-time STM32H743 flight controller with its own IMU, barometer and compass, on a HAT that plugs into the 40-pin header. The flight controller runs PX4, ArduPilot or Betaflight and flies the aircraft, while the Pi (or a Jetson, ST or TI dev kit) runs your vision, autonomy, video and networking, linked over MAVLink. One 2S–6S battery powers both.
About this product
Features and specifications
Features
- STM32H743 flight controller (480 MHz) with an ST IMU, barometer and magnetometer
- PX4, ArduPilot and Betaflight support, linked to the host over MAVLink or MSP
- The host can update the flight controller firmware in the field
- flightHAT and host both run from the ESC connector, just like any other flight controller
- On an input overload the host is switched off and the flight controller keeps flying, so it can failsafe safely
- Standard connectors: Pixhawk JST-GH for GPS, CAN and telemetry; Betaflight JST-SH for the 4-in-1 ESC and receiver
- Raspberry Pi Zero size with breakaway tabs for Raspberry Pi 4 / 5 mounting
- Designed for NDAA compliance
Specifications
| Flight controller | STM32H743, Arm Cortex-M7, 480 MHz, 2 MB flash, 1 MB RAM |
|---|---|
| Sensors | IMU, barometer, magnetometer |
| Flight stacks | PX4 (primary), ArduPilot, Betaflight |
| Battery input | 2S–6S (6.0–26.1 V) |
| Host power output | 5.2 V, up to 3 A |
| Motor outputs | 4 × DShot (4-in-1 ESC connector) |
| Ports | DroneCAN, GPS, RC IN, TELEM1, 2 × host peripheral ports, USB-C |
| Logging | microSD |
| Size | 65 × 30 mm (65 × 56 mm with tabs) |
| Mounting | M2.5, Raspberry Pi Zero and Pi 4 / 5 hole patterns |
| Operating temperature | −20 to +50 °C |
| Weight | TBD |
Technical details
Ports and compatibility
Supported hosts
| Host | Notes |
|---|---|
| Raspberry Pi 5 | Primary target. Mount with the tabs on; powered by flightHAT (3S or more recommended) |
| Raspberry Pi 4 Model B | Primary target. Mount with the tabs on; powered by flightHAT (3S or more recommended) |
| Raspberry Pi Zero 2 W | Primary target. Tabs off; powered by flightHAT from any pack. Needs a 40-pin header fitted; HOST UART not available |
| NVIDIA Jetson Orin Nano / NX dev kits | Header only. Needs its own 9–20 V supply; flow control needs a pinmux change |
| STMicroelectronics STM32MP257F-DK | Header only; powered by flightHAT |
| Texas Instruments SK-AM62A-LP | Header only. Needs its own supply; host link without flow control |
| Orange Pi Zero 3W | Pi Zero size; powered by flightHAT (3S or more at full load). Host link without flow control; HOST UART not available. Not NDAA (Chinese maker and SoC) |
Flight stacks
| Stack | Support |
|---|---|
| PX4 | Primary (MAVLink) |
| ArduPilot | Supported (MAVLink) |
| Betaflight | Supported (MSP) |
Preliminary. flightHAT is in development (hardware revision X1); specifications may change before release. Contact us about volume orders, integration or early access.
Includes
What's in the box
- 1×flightHAT board, breakaway tabs attached
- 4×Nylon spacers, 11.1 mm
- 4×M2.5 × 25 mm nylon pan-head screws
- 4×M2.5 nylon hex nuts
From the blog
Learn more
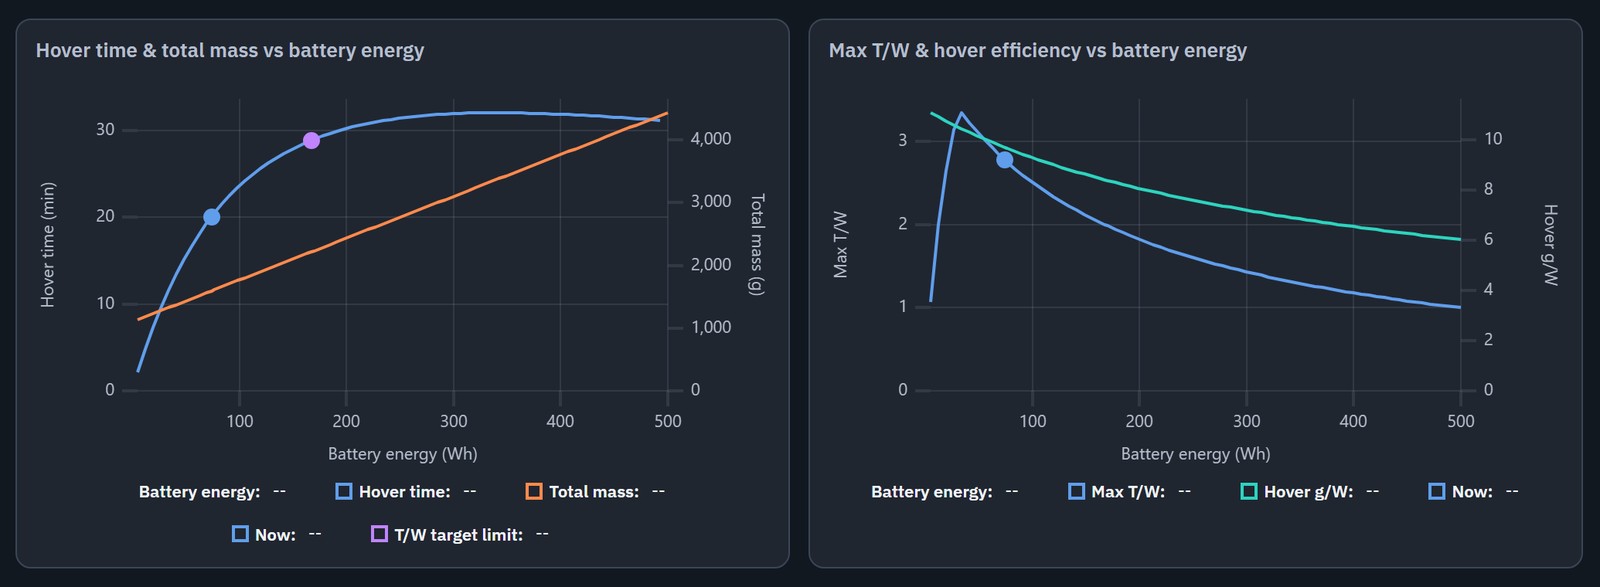
Designing a drone powertrain: motor, propeller and battery
A walk through sizing the propeller, motor KV, battery and cell count for a multirotor, the physics behind each choice and the constraints that end up deciding the design, with live calculator examples.
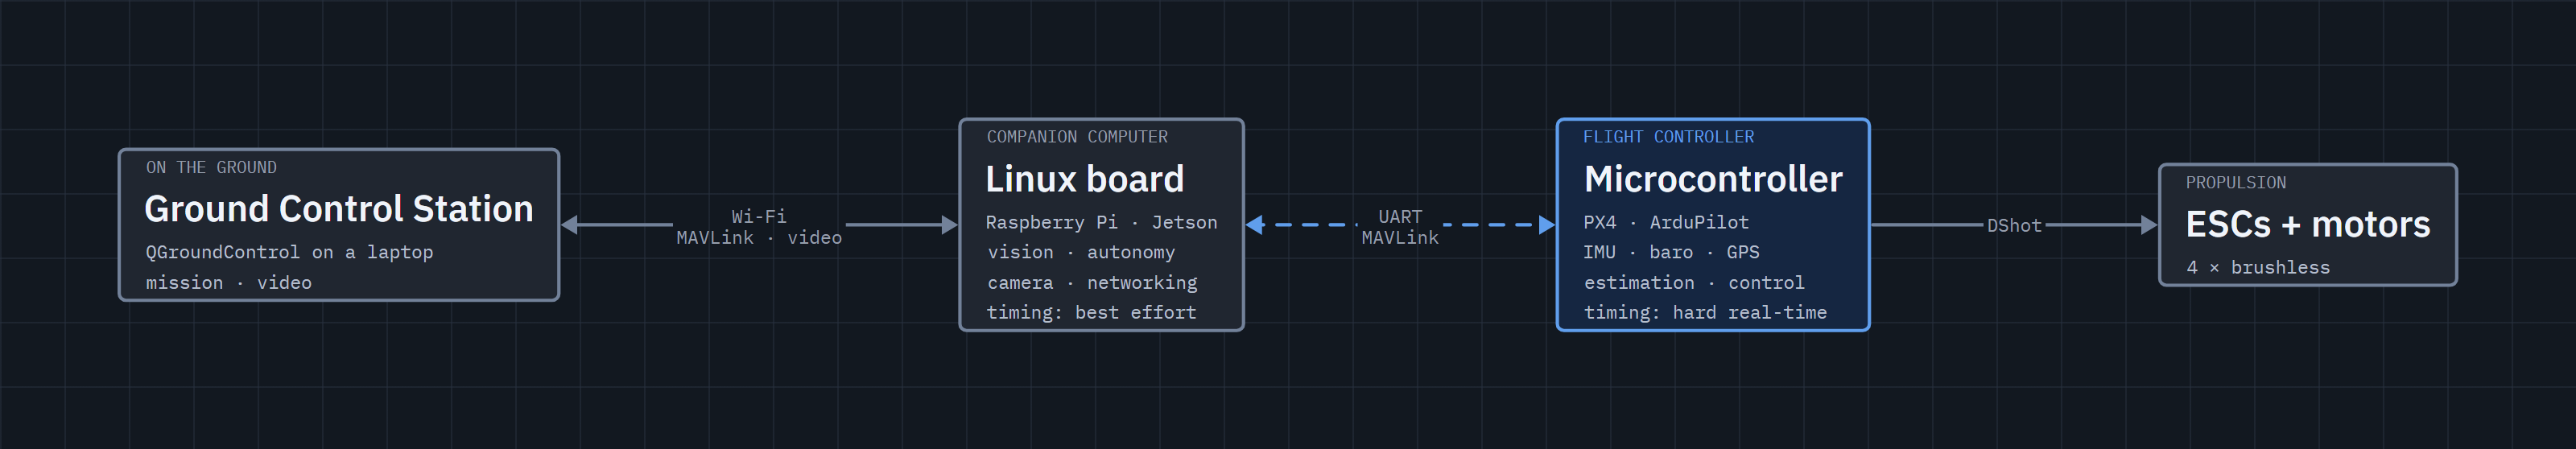
Flight controller vs. companion computer: who does what on a drone
Why most capable drones carry two computers, what each one is responsible for, and how they talk to each other over MAVLink.